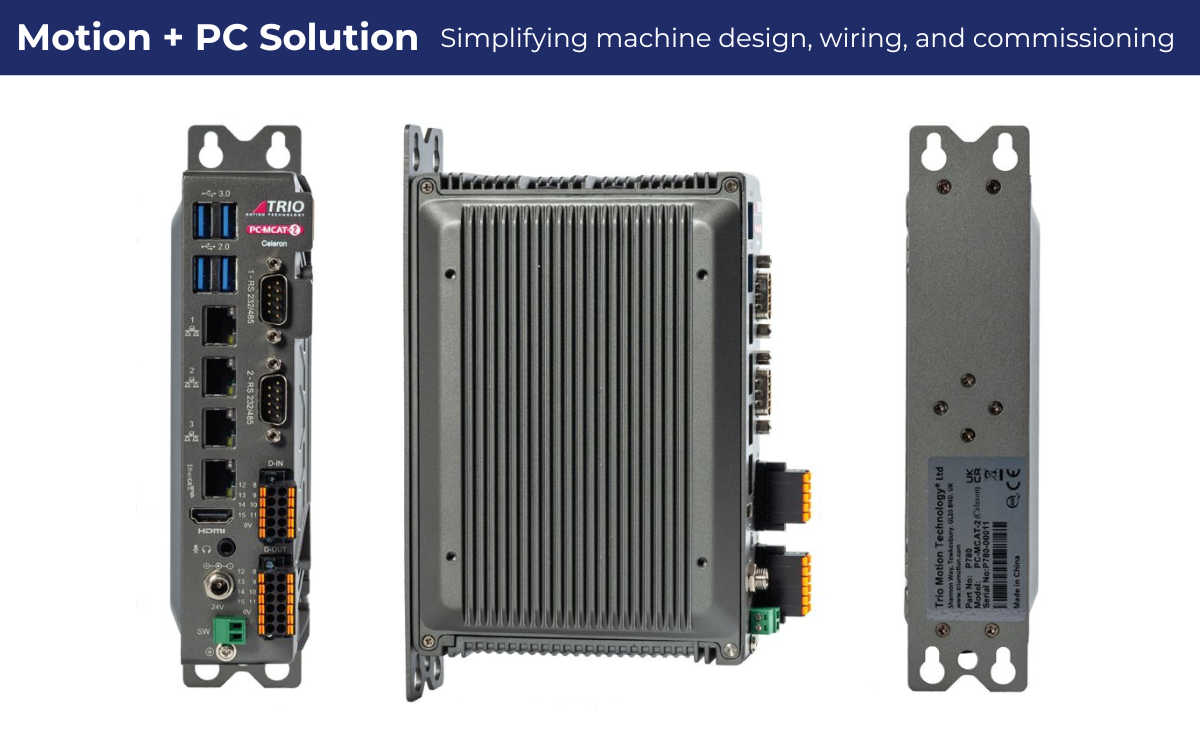
The PC-MCAT-2 is a proven solution in industrial automation and motion control systems, combining an industrial PC with a dedicated PC-based motion controller in a single integrated platform.
It is widely used in machine design where engineers require a compact and scalable approach to multi-axis motion control, system integration, and high-performance automation.
PC-Based Motion Control for Machine Automation
The PC-MCAT-2 brings together computing and motion control within one device to simplify machine architecture while maintaining deterministic performance.
The industrial PC handles higher-level functions such as:
- HMI (Human Machine Interface) applications
- Machine software and process control
- Communication, monitoring, and diagnostics
Alongside this, the integrated motion control engine delivers real-time execution for:
- Multi-axis motion control
- Coordinated and synchronised movement
- Precision machine operations
This separation ensures stable motion performance, independent of operating system load, which is a key requirement in modern machine automation controllers.
Industrial Connectivity and EtherCAT Integration
The PC-MCAT-2 is designed for seamless integration into modern automation environments using high-speed industrial networking, including EtherCAT motion control systems.
It typically interfaces with:
- Servo drives and motor systems
- Distributed I/O modules
- Operator panels and HMI interfaces
This enables flexible deployment across standalone machines as well as larger, networked production systems.
Engineering Benefits
Integrated PC-based motion platforms continue to be widely adopted in industrial machine design due to their balance of performance and simplicity.
Key advantages include:
- Reduced hardware complexity in automation systems
- Simplified wiring and cabinet design
- Scalable architecture for expanding machine requirements
- Reliable performance in multi-axis motion control applications
- Flexible integration into existing industrial infrastructure
Summary
The PC-MCAT-2 remains a strong example of a PC-based motion controller approach, combining industrial computing with real-time motion execution. Its integration capabilities and EtherCAT connectivity make it well suited to modern industrial motion control systems where performance, scalability, and efficiency are key design requirements.
Discuss your application
Contact us to see how this solution could fit your system.